01/10/2025
10:37 UTC+1
Page size: 1.024 Mo
load time: 0.04Ms
ce site utilise des cookies_

ODYSS:AI — Full Autonomy for Ocean Cleanup

maritime activity icon in greenRobotics activity icon in green
activitY:
Maritime & Robotics
expertise:
computer science
Modelling & Simulation
ARTIFICIAL INTELLIGENCE
plus iconplus iconplus iconplus icon

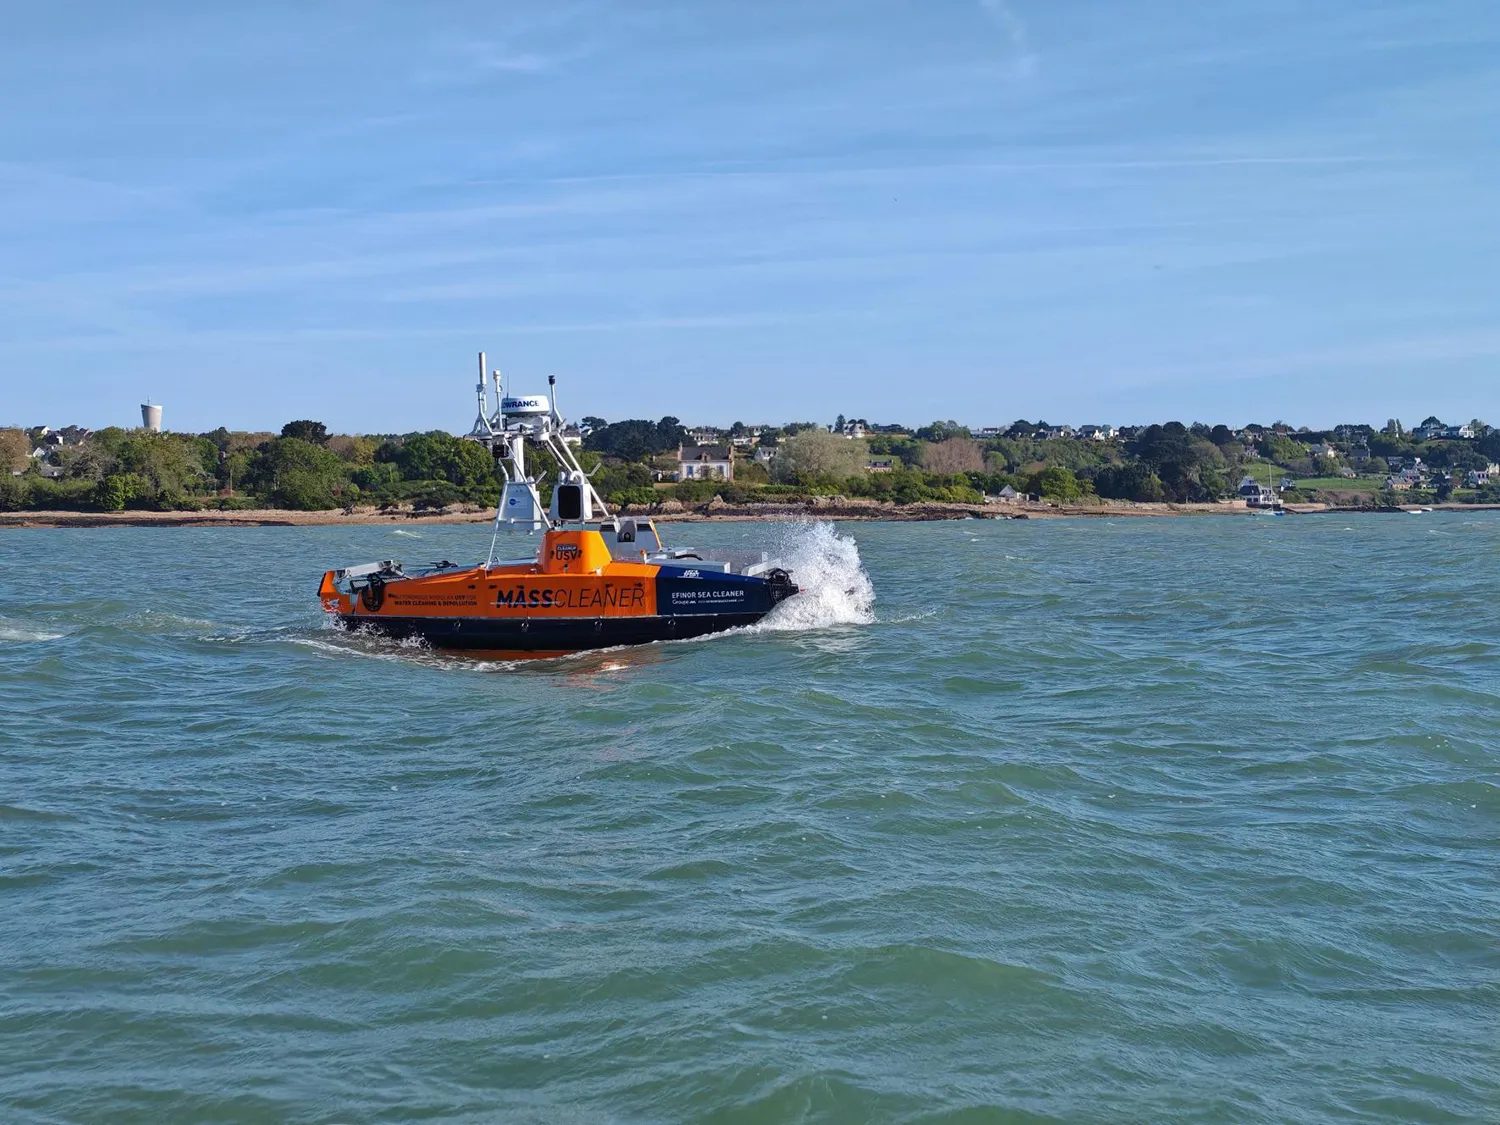
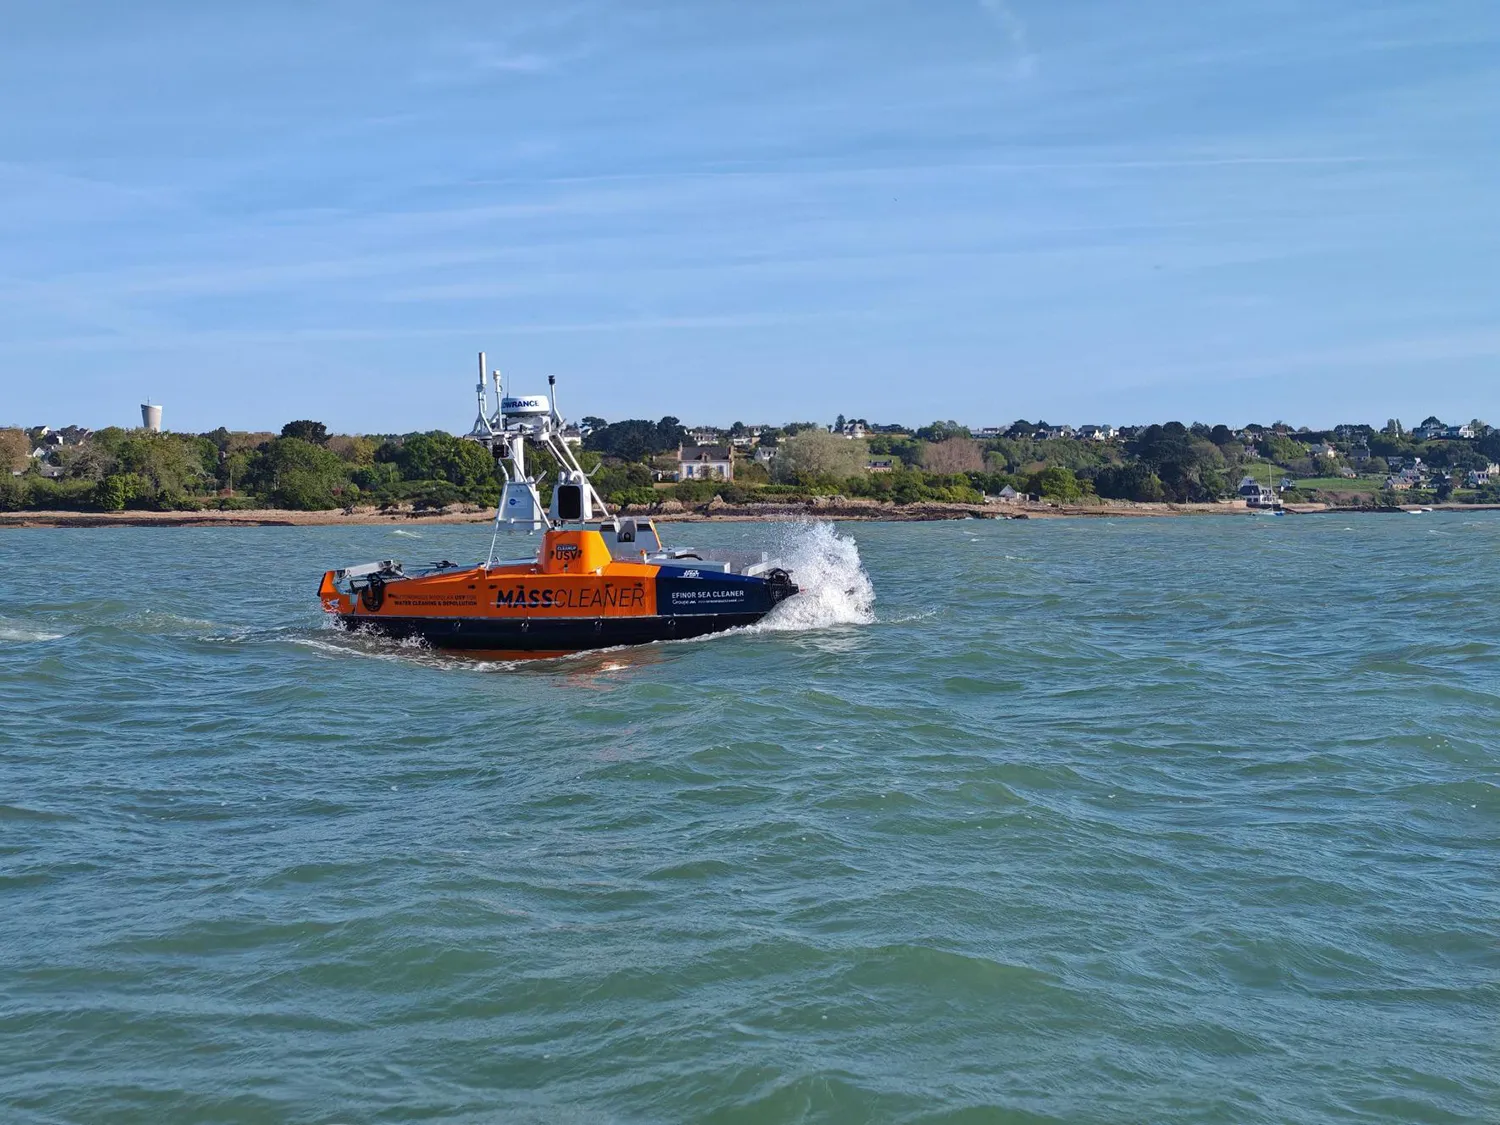
Autonomous detection and collection of marine litter requires every link in the chain, from perception to decision-making, to be made reliable. To meet this challenge, our team designed and tested a full autonomy system for Efinor Sea Cleaner's Mass Cleaner maritime drone. The system can perceive its environment, build a tactical picture, and plan or adapt its missions in real time to navigate safely.

context
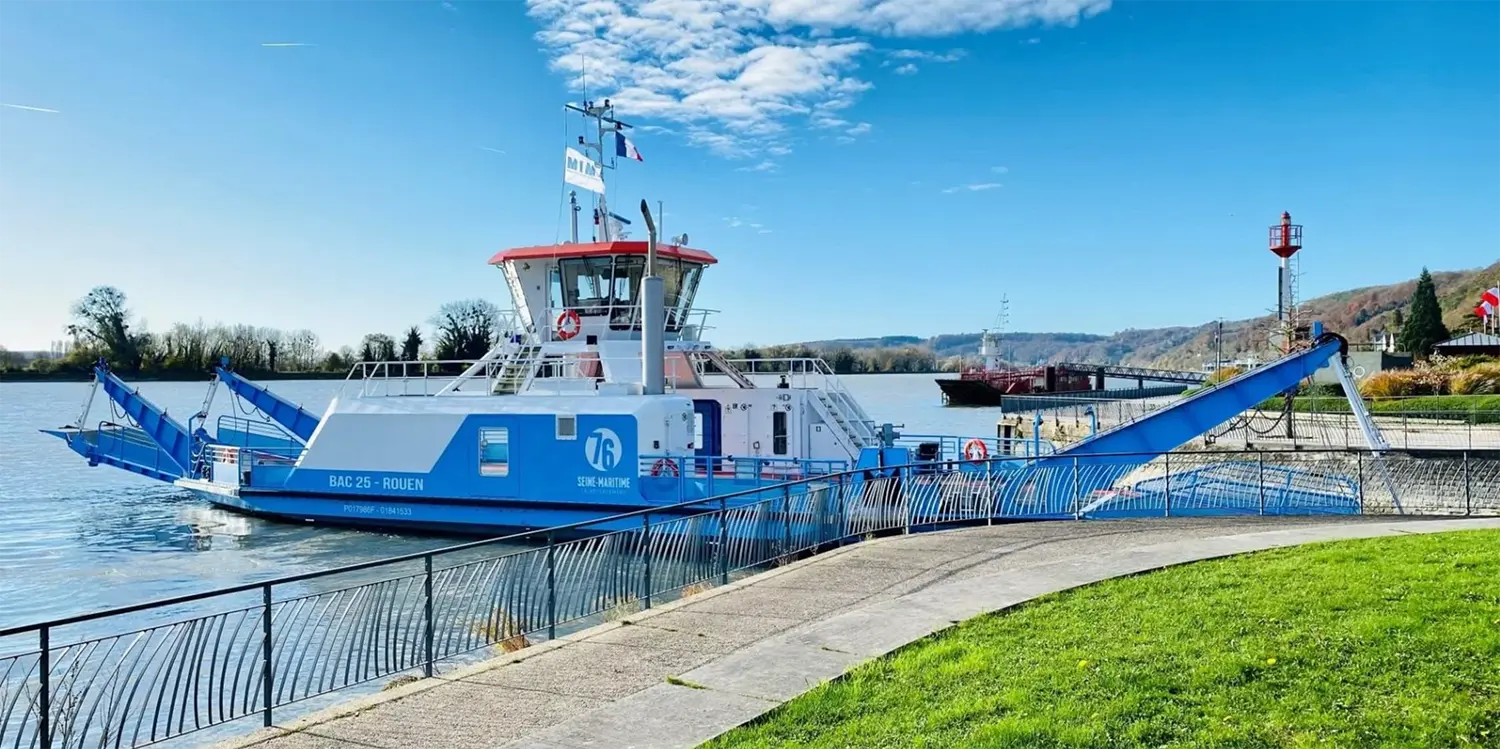
The project aims to automate the detection and recovery of floating waste (bottles, floating debris, oil slicks, etc.) by the Mass Cleaner maritime drone, in partnership with Efinor Sea Cleaner. Based in Paimpol, this French company designs multipurpose vessels dedicated to cleaning seas, rivers and ports, and has delivered more than 170 units. The Mass Cleaner is its surface drone, capable of operating either remotely or autonomously.

Reducing the need for manual supervision is a key lever for scaling up, but it must not come at the expense of safety or reliability. To enable the algorithm to accurately perceive its environment, detect obstacles and plan its movements autonomously, our team developed several technology building blocks: sensor data fusion, construction of a consistent tactical picture, mission planning and adaptation to local contingencies, and management of interactions with a human operator, who supervises operations and can approve the collection of detected waste when there is uncertainty.

Before any deployment on the Mass Cleaner, we needed to be able to test, simulate and replay all of these behaviours in a controlled environment that faithfully reproduces navigation conditions (waves, currents, sensor noise) as well as the other entities around the boat.
innovations
To transform a collection of disparate technology building blocks into a robust, self-contained system, our team implemented several innovations spanning simulation, testing, and industrialization.
On-Board Dynamics Simulator
minus iconplus icon
Development of a simulator that replicates the dynamics of the Mass Cleaner and generates realistic sensor data (motion, noise, AIS signals from surrounding objects), including environmental forces such as waves and currents.
Tactical Situation and Data Integration
minus iconplus icon
Construction of a coherent tactical picture based on simulated or real sensor data, enabling the system to detect obstacles and surrounding objects (including debris) in real time.
Planification de mission adaptative
minus iconplus icon
Développement d'une planification otpimisée des missions, et de la capacité de générer des manœuvres d'évitement d'obstacles puis de reconstruire une trajectoire de retour vers la mission initiale.
Test and Replay Architecture
minus iconplus icon
Implementation of a comprehensive test bench that allows users to view behavior in real time, simulate data, or replay past real-world scenarios for analysis or debugging.
Industrialization of Algorithmic Building Blocks
minus iconplus icon
Consolidation of the various algorithms developed separately into a single architecture, ready for deployment and testing on the Mass Cleaner.
SOLUTION

Develop and integrate innovative algorithmic building blocks into a fully autonomous system that is ready for field use.

This architecture now enables the Mass Cleaner to perceive, decide, and act in real time, while still allowing certain critical decisions to be validated by an operator.

benefits
Thanks to this architecture, Efinor Sea Cleaner now has a system capable of operating autonomously while remaining controllable. The concrete benefits are as follows:
01

Real-time obstacle detection and avoidance in compliance with navigation rules

02

Validation of Algorithmic Approaches Using a Testing Framework

03

Consolidation of algorithms into a single, modular architecture

Footer Gradient

a single conversation can spark Innovation